OEM Hall Current Sensor Selection: Key Factors for Accurate Current Sensing
2026-08-28
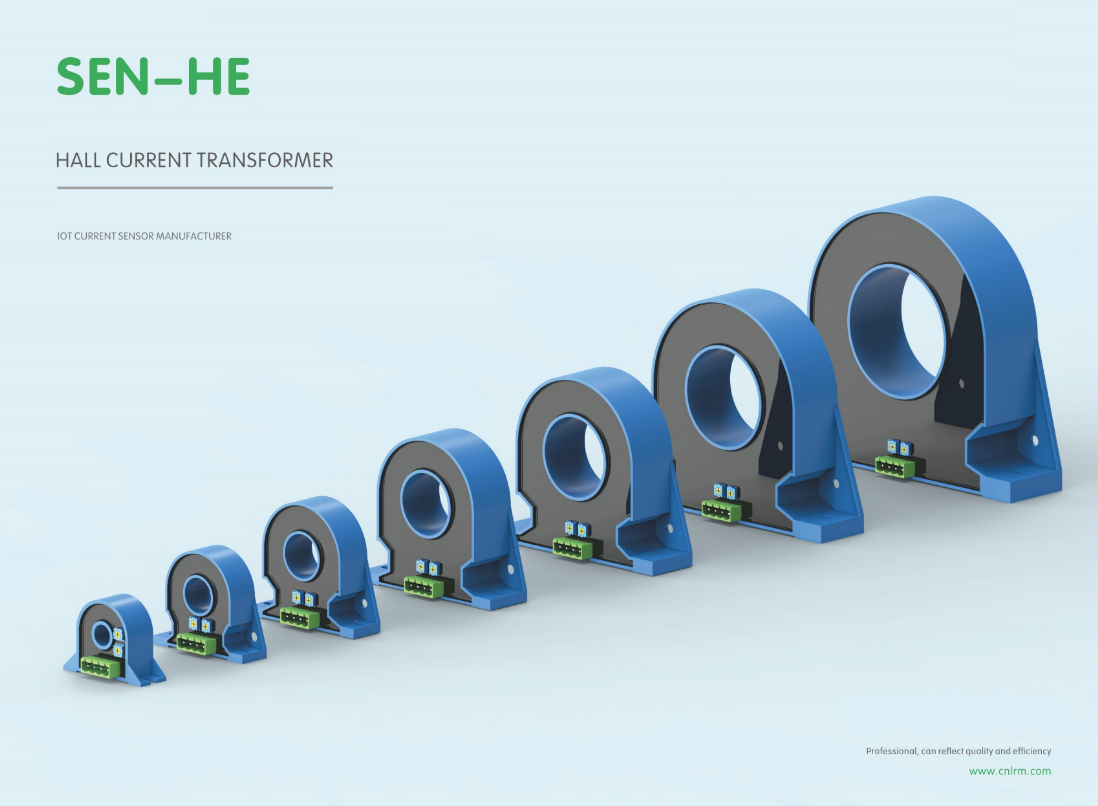
Selecting the right Hall current sensor for an OEM design isn't just about picking a part that fits the board. Accuracy, bandwidth, temperature drift, and isolation requirements can quietly undermine performance if overlooked. At Xiasen, we've seen too many projects stall because the sensor was treated as an afterthought. This guide breaks down the key factors that actually determine whether your current sensing stays accurate over the full operating range—and how the right OEM partner can make that choice simpler.
Your Current Profile Isn't a Sine Wave
Think of a sine wave: smooth, predictable, symmetrical. Now hold that image up against your actual daily output, your sleep schedule, your creative drive, or even your heart rate variability. The gap between the idealized curve and the jagged, uneven line of lived experience isn’t a flaw—it’s evidence of a complex system responding to real-world friction. Your current profile isn’t a sine wave, and that’s not just okay; it’s the raw material for insight that a clean mathematical model would never give you.
When we assume our performance should follow a neat periodic pattern, we set ourselves up for frustration. The truth is messier: a stretch of low amplitude might hide a pending shift, a sudden spike might be noise rather than signal, and the phase of your energy can drift in ways no Fourier transform will capture. Treating these deviations as data instead of defects lets you tune your approach—adjusting rest, input, or output—without demanding a false smoothness from yourself.
The next time you look at a dashboard, a habit tracker, or a performance chart and notice it doesn’t resemble a perfect oscillation, resist the urge to flatten it. That irregular profile is a record of adaptation, interruption, and recovery. It’s less like a textbook waveform and more like a signature: unique, informative, and impossible to replicate by simply turning a knob on a signal generator.
Core Materials That Don't Sweat the Heat
When temperatures climb past the point where most metals turn soft and plastics lose their shape, a handful of materials simply shrug. Ceramic matrix composites, for instance, combine ceramic fibers with a ceramic matrix to create something that stays rigid at temperatures that would melt steel. Aerogels go a different route: their porous, almost ghost-like structure traps heat so effectively that one side can face a blowtorch while the other stays cool to the touch. These aren't exotic lab curiosities anymore; they're showing up in turbine blades, spacecraft heat shields, and even high-end cookware.
The trick often isn't just withstanding heat but managing it gracefully. Nickel-based superalloys get their staying power from carefully arranged crystal structures that resist creep, the slow deformation that kills most metals under sustained thermal stress. Meanwhile, some modern composites use layered carbon or graphite to spread heat sideways instead of letting it build up in one spot. The result is a material that doesn't need bulky cooling systems to survive, because it was built from the start to treat high temperature as just another working condition.
Why Offset Drift Matters More Than Initial Accuracy
When a sensor or measurement system first comes off the production line, its zero-point error often looks negligible. The initial accuracy might be within a few millivolts or a fraction of a degree, and that feels reassuring. But in continuous operation, drift accumulates silently: temperature swings, mechanical stress, aging components, and even humidity gradually push the reference point away from where it was calibrated. A device that starts out nearly perfect can end up several percent off after weeks or months—not because it was badly made, but because the environment never stops acting on it.
The real problem with drift is that it's insidious. A sudden offset error is usually caught by a self-test or by a visible mismatch in the data, but slow drift looks just like a valid change in the measured quantity. A pressure sensor on an industrial line might drift upward by 2% over a month; the control system interprets that as a genuine rise in line pressure and adjusts valves accordingly. By the time someone notices the discrepancy, the process has been running on wrong numbers for days. That's why field engineers often say: give me a stable sensor with mediocre initial accuracy over a high-precision one that drifts—because I can compensate for a known offset, but I can't compensate for an offset I don't know is there.
Compensation and calibration loops can help, but only if they are designed for the drift mechanism, not just the initial error. For example, periodic zero-point re-referencing, differential measurements, or using a reference channel that drifts in the same way as the sensing channel can cancel out much of the common-mode drift. In many applications, the long-term repeatability—how closely the system returns to the same value under the same conditions over months or years—becomes more important than the out-of-the-box accuracy. Once you accept that drift is a process rather than a spec, you start building systems that stay useful long after their initial calibration sheet has become a historical document.
Fast Edges Need More Than High Bandwidth
A common mistake in high-speed design is treating bandwidth as the only metric that matters. A system can have impressive headline bandwidth and still produce distorted waveforms when edge rates are fast. The culprit is usually the parasitics that become significant at short rise times—inductance in return paths, capacitance at connectors, and impedance discontinuities along the signal path all contribute to ringing, overshoot, and eye closure.
To handle fast edges cleanly, the entire channel needs to be treated as a distributed element, not a lumped connection. That means paying attention to stackup, via transitions, and reference plane continuity. Even small gaps in a ground plane under a fast edge can cause noticeable reflections. Designers often find that lowering the inductance of the return loop and keeping the signal's characteristic impedance consistent matter more than adding raw bandwidth to a component.
Component datasheets may advertise bandwidth, but the actual edge fidelity depends on how the part behaves in the context of the board. A fast comparator or amplifier can lose its advantage if the layout forces the signal through a narrow trace with no adjacent return via. Good practice is to simulate the transient response with realistic models, not just swept s-parameters, because the time-domain behavior of the edge exposes problems that frequency-domain bandwidth plots hide.
Creepage and Clearance: The Unseen Specs
Most engineers treat creepage and clearance as a box-ticking exercise on a PCB layout checklist, but these two distances quietly decide whether a design survives moisture, dust, and voltage transients. Clearance is the shortest path through air between two conductive parts, while creepage follows the surface of the insulating material. The difference matters because air breaks down predictably, but a contaminated board surface can arc at far lower voltages—especially when humidity condenses on dust or flux residue.
The real headaches start when you layer in working voltage, pollution degree, and material group. A 400V board that passes in a clean lab might fail in a coastal enclosure after months of salt spray. Comparative tracking index, or CTI, becomes the quiet arbiter: a low-CTI substrate shrinks allowable creepage even if clearance looks generous. Standards like IEC 60664 and UL 840 exist to stop you from guessing, but they can't tell you which pollution degree your product will actually face in a tractor cab or a rooftop inverter.
Many failures trace back to a single overlooked gap near an uncoated slot, a board edge too close to a screw, or a conformal coating that was assumed to fix everything. The specs are unforgiving because they are invisible—you don't see the arc until it's already carbonized the board. Treat creepage and clearance as a thermal or mechanical constraint, not an afterthought, and your next field return won't come with a scorched PCB photo.
Calibration Isn't a One-Time Event
Calibration often gets treated like a checkbox on a commissioning form. You run your standard, adjust the offset, sign the sheet, and assume the instrument is trustworthy for the next year. But sensors drift unevenly depending on temperature cycles, vibration, contamination, and even how often they're powered on. A one-time calibration only captures a snapshot under one set of conditions. Real-world performance is messier, and the gap between that snapshot and actual field behavior grows quietly over time.
What matters more is building a calibration schedule that reflects how the instrument is actually used. A pressure transmitter in a stable lab may hold its accuracy for months, while the same model bolted to a compressor skid might need weekly checks. Instead of relying on fixed intervals, watch the trend data. If repeated calibrations show minimal correction at three months, extend the window slightly. If you're catching drift before it affects product quality, shorten it. The goal isn't to satisfy an auditor's calendar—it's to know when the device is about to leave its tolerance band.
Operators also need to see calibration as a feedback loop, not a periodic event. Keep a simple log of as-found versus as-left values, and flag instruments that need frequent adjustment. Often, a high drift rate points to a deeper issue: a failing diaphragm, moisture in the electronics, or a bad installation. Fixing that root cause does more for reliability than calibrating more often. The moment you stop treating calibration as an isolated task and start seeing it as ongoing health monitoring, you get fewer surprises on the line.
FAQ
Open-loop designs rely on the Hall element's raw output, so any residual voltage from manufacturing tolerances or mechanical stress directly shifts the zero-current reading. Closed-loop sensors continuously null the core flux, which makes them far less sensitive to those initial offsets.
Silicon steel cores handle high flux without saturating but add hysteresis and remanence, which show up as nonlinearity after a large overload. Ferrite cores offer lower losses and better high-frequency behavior, yet they saturate sooner and can latch a residual field that corrupts low-current readings until degaussed.
Programmable outputs let you adjust gain and offset after installation, which helps when the same sensor must work across different busbar geometries or when system calibration has to compensate for nearby magnetic fields. Fixed outputs reduce setup steps but leave less room to correct drift or mechanical misalignment.
You need at least ten times the PWM frequency if you want to capture current ripple and transient overshoot without aliasing. A 200 kHz sensor is usually sufficient for 20 kHz switching, but if you're doing predictive control or fast overcurrent protection, push toward 500 kHz and check the phase delay at your control loop crossover.
Two separate effects appear: sensitivity drift from the Hall element's temperature coefficient and offset drift from stress on the die and package. Sensitivity changes scale the whole measurement, so a 100 A reading can shift by a few amps across a 60°C span, while offset drift adds a fixed error that hurts accuracy at low currents most.
A ratiometric output tracks the supply voltage, so if the 5 V rail droops 2%, the sensor's zero and full-scale points move the same percentage. That can actually improve accuracy when the ADC uses the same rail as its reference. Non-ratiometric outputs stay fixed regardless of supply, which is better when the sensor powers from an unregulated rail but the microcontroller's reference is precise.
Aim for at least 8 mm creepage and 8 mm clearance if pollution degree 2 applies, but most automotive and industrial designs target 10 mm or more to handle altitude derating and conformal coating variations. The isolation barrier also needs to withstand the working voltage plus transient overvoltages, so check the partial discharge rating rather than relying on the basic isolation voltage alone.
Keep the sensor at least 2-3 conductor diameters away from other high-current paths, and orient its sensing axis perpendicular to stray fields you cannot avoid. Adding a magnetic shield around the core only works if the shield does not create a low-reluctance path that concentrates the interfering flux into the gap.
Conclusion
Selecting a Hall current sensor for OEM designs starts with recognizing that real motor drives, inverters, and DC-DC stages rarely produce clean sine waves. The actual current often carries switching harmonics, DC offsets, and sharp transient edges. A sensor rated only by its -3 dB bandwidth may still miss fast di/dt events if its internal slew rate or response time is inadequate. Equally important is the magnetic core: grain-oriented silicon steel may look efficient on paper, but under continuous high-temperature operation its permeability shifts and the output drifts. A core material with stable behavior across the thermal range keeps the measurement trustworthy without adding complex compensation circuits. Initial datasheet accuracy figures are far less meaningful than offset drift over the lifetime, because even a small offset error integrates into control loops and battery state estimation.
On the isolation side, creepage and clearance distances often get ignored until a compliance test fails. High-voltage systems demand more than just a rated isolation voltage; pollution degree, altitude, and board layout all interact with those physical gaps. A sensor with tight creepage margins may pass bench tests yet break down after humidity or dust accumulation. Calibration also cannot be treated as a single factory step. Core aging, mechanical stress, and repeated thermal cycling cause gain and offset to wander in ways that simple initial trimming cannot predict. OEM teams that build in periodic or condition-based recalibration—or select sensors with inherently low long-term drift—avoid field failures and expensive recalls. Taken together, these factors make Hall sensor selection a systems-level decision, not a simple comparison of nominal specs.
Contact Us
Contact Person: Liu Mengyang
Email: [email protected]
Tel/WhatsApp: 8618727589233
Website: https://www.cnlrm.com/en/